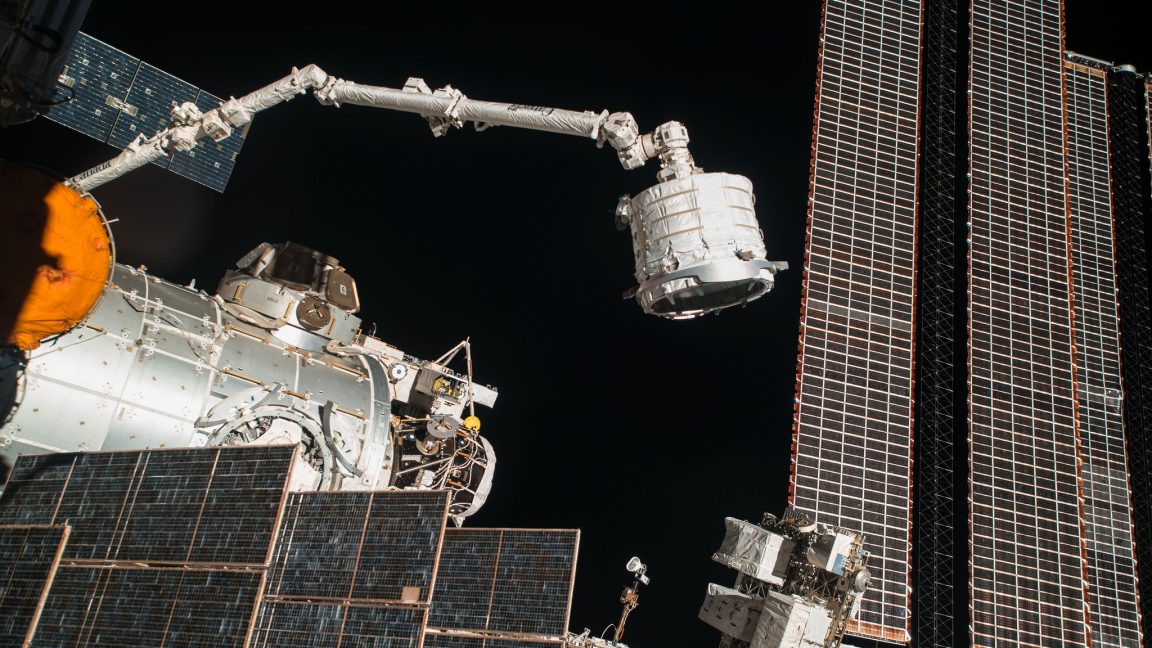
NASA is currently addressing operational issues with the Canadarm2, the robotic arm aboard the International Space Station (ISS). This follows a routine maneuver known as a "walk-off," during which the arm, measuring 58 feet in length and supplied by the Canadian Space Agency, encountered some problems. The arm is designed to move along the exterior of the ISS, functioning like an inchworm due to its symmetrical design.
Current Situation
As of Sunday evening, engineers are investigating whether the issues stem from a data or software malfunction, or if they are related to the hardware of the robotic arm or its mobile transporter.
On Monday at 2 PM ET, NASA provided an update stating that the Canadarm2 is currently operating as expected and is being utilized for the inspection of the Crew-12 Dragon spacecraft as part of predeparture procedures. However, non-robotic components associated with the mobile transporter on the truss have shown communication errors.
Troubleshooting Efforts
NASA is actively troubleshooting these errors before the next movement of the transporter from its current location, designated as Worksite 6. In addition, NASA and SpaceX are collaborating to ensure that there is no GPS interference affecting the Dragon's docking capability with the station's forward port due to the transporter’s position. Joint teams are conducting analyses and expect to resolve the issue before the Crew-13 launch.